Motor controller for robotics actuators
Compact circular motor controller PCBs with field-oriented control and CAN-FD for a family of dynamic robotics actuators in three form factors, including full CAN protocol documentation and an end-of-line test plan.
- Mechanical engineering
- Electronics
The problem
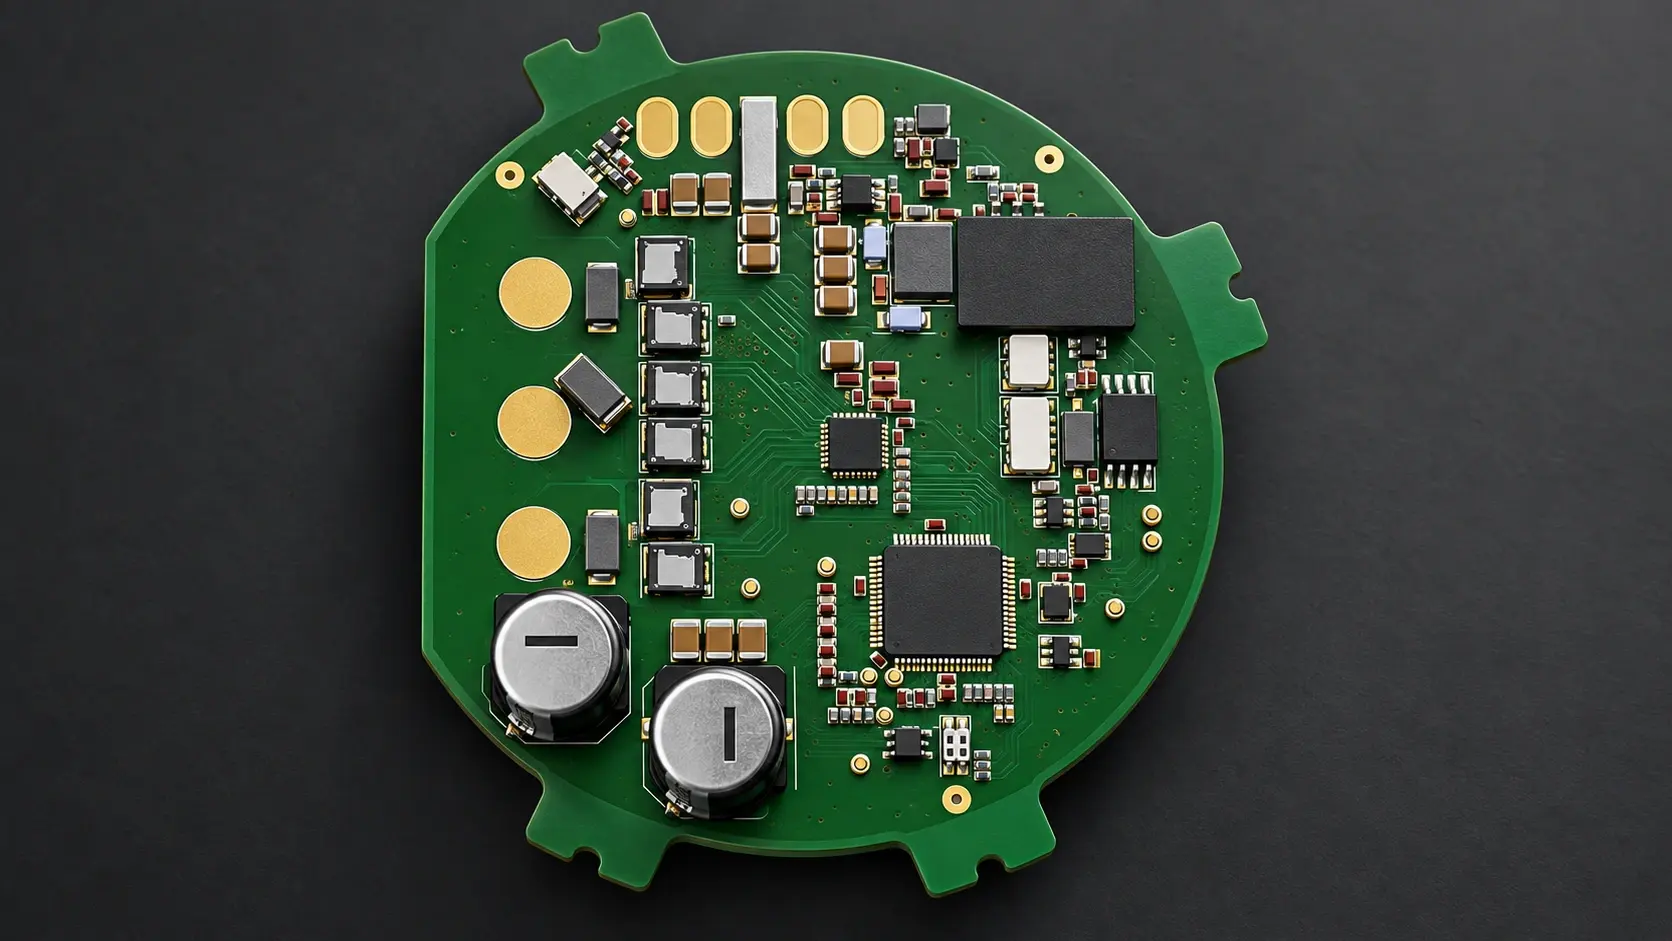
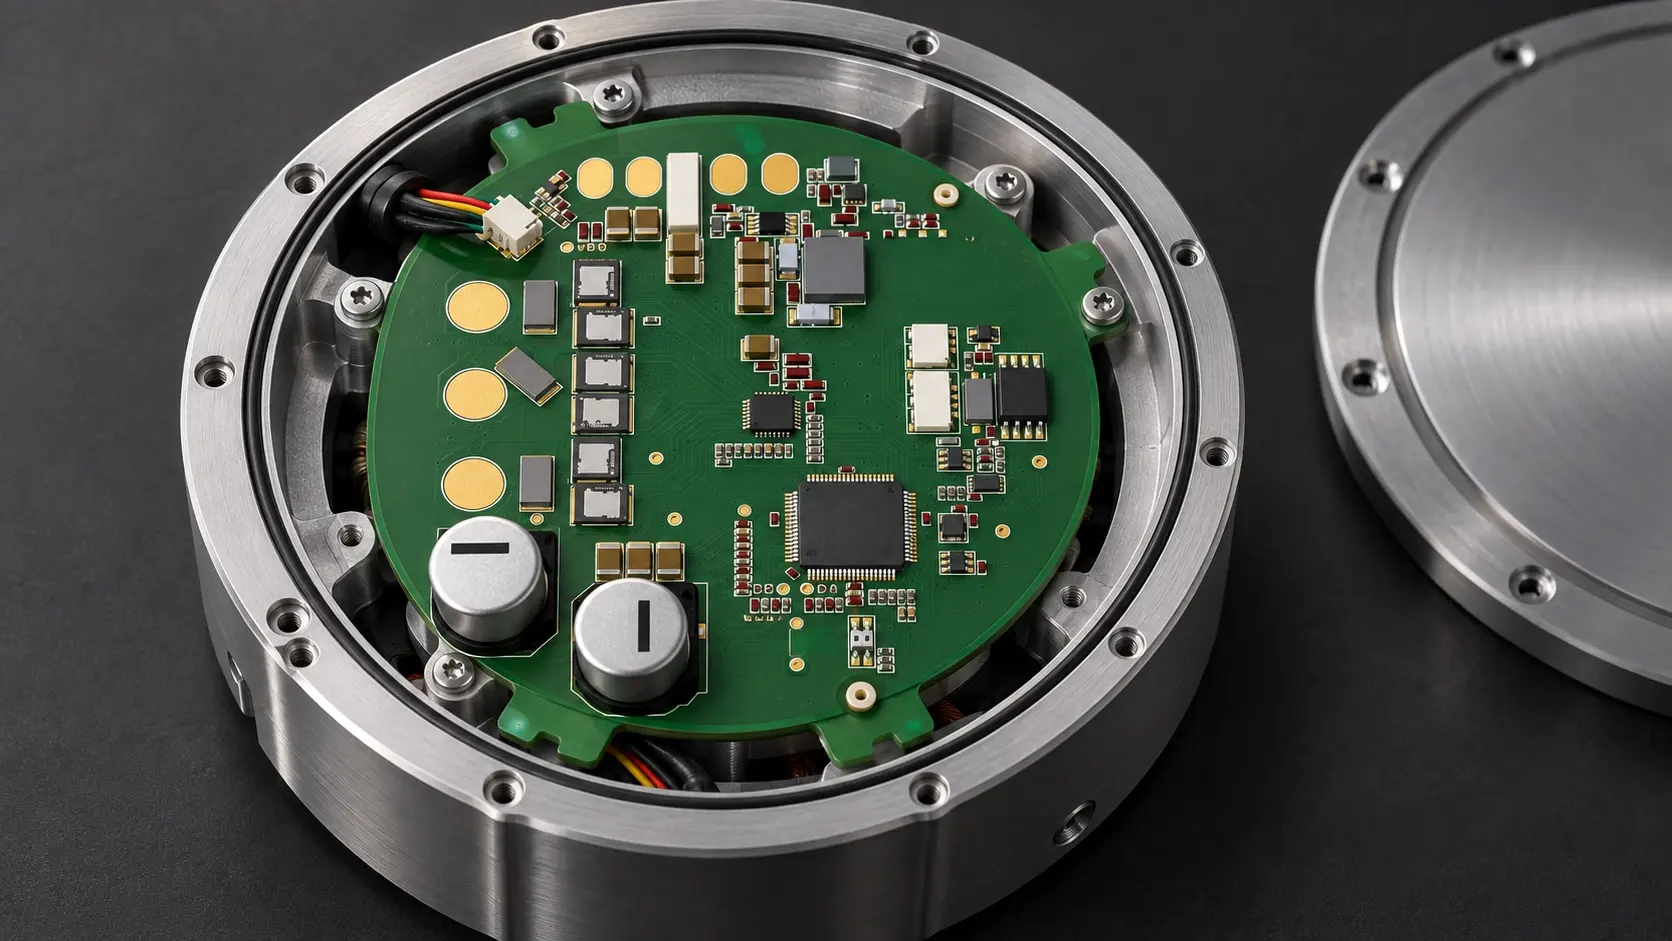
The customer was developing dynamic robotics actuators in three form factors (XA2, XA4, XA5) and needed a custom motor controller for each. The PCBs must fit directly into the cylindrical actuator housing — circular layout, minimum footprint.
A supply voltage range of 18–70 VDC and a tight mechanical envelope set demanding requirements for power electronics and thermal management. Multiple actuators must be controlled via CAN-FD in a daisy-chain topology from a single host.
Alongside the hardware, the team needed complete CAN/CAN-FD protocol documentation and a production-grade ICT/FCT test plan for automated end-of-line testing of every board.
Our approach
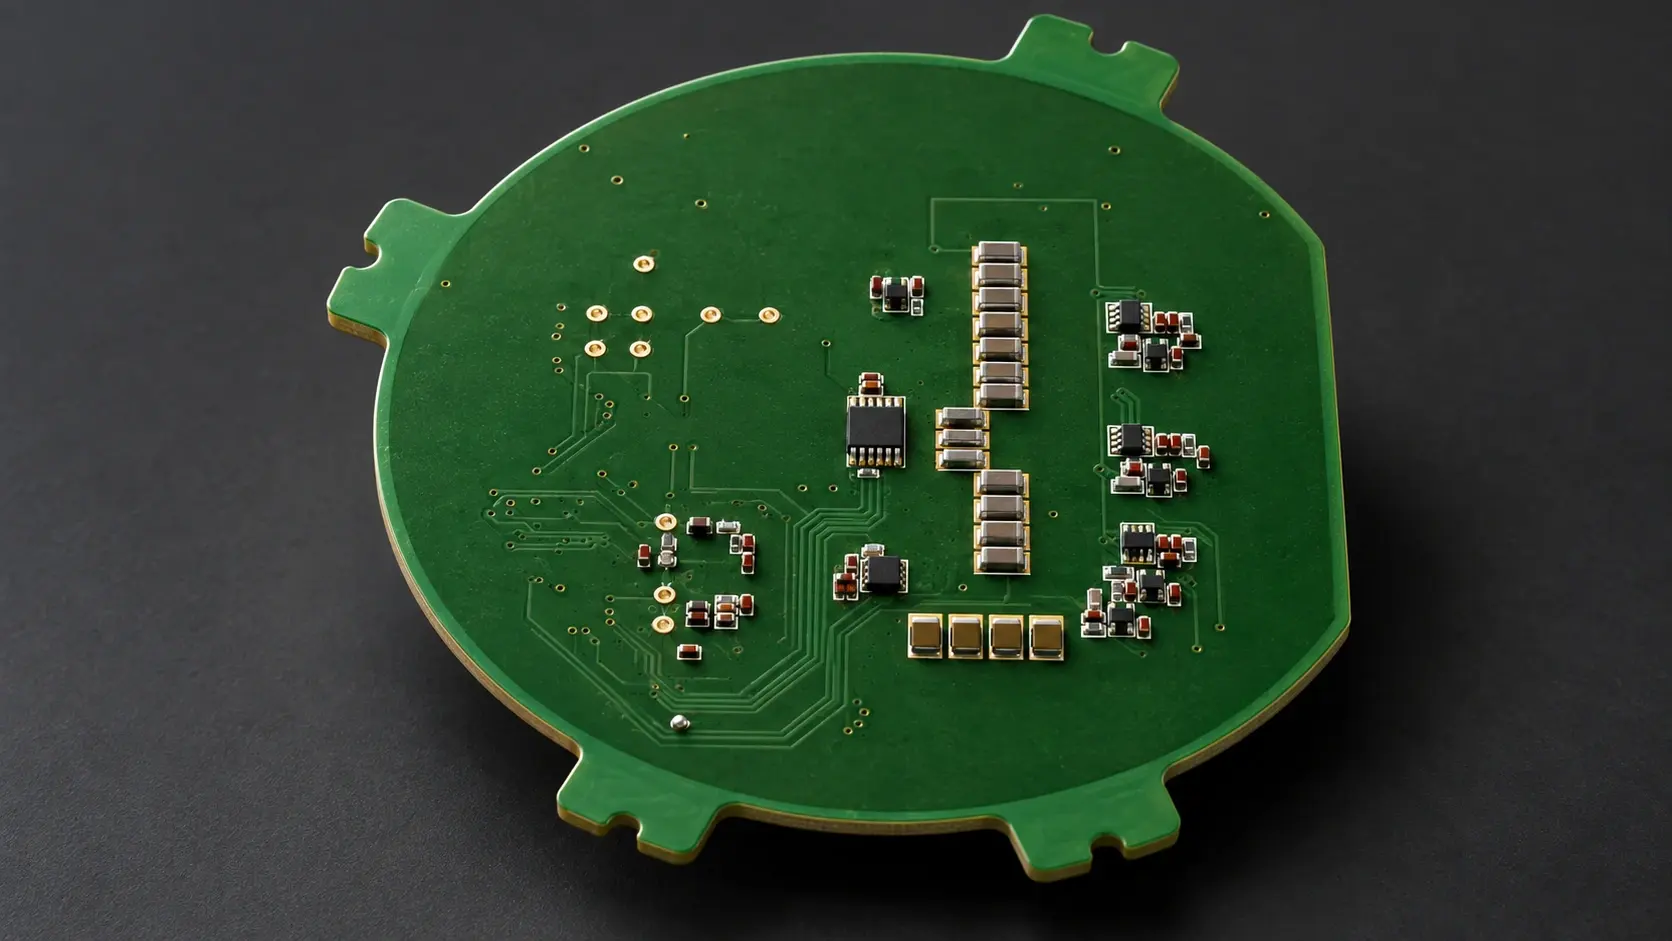
Akrodyn developed two successive motor controller generations: MCL V2.1.1 for the XA4 and MCB3 V3.0.0 for the XA5 form factor. Both follow a circular PCB layout that mounts directly inside the actuator housing without modification.
The firmware implements field-oriented control with sensor fusion combining encoder and observer for electrical angle estimation. A power state machine provides defined startup sequencing, damping mode as a failsafe, and keep-alive supervision over CAN.
CAN and CAN-FD (up to 3 Mbps data rate, 1 Mbps nominal) were fully integrated: up to 127 addressable devices per bus, with configurable streaming of motor status, current and position data in real time.
Akrodyn authored the CAN/CAN-FD protocol documentation and maintained it over 31 versions alongside the customer. For series production, Akrodyn delivered an ICT/FCT test plan for automated end-of-line testing of every board.
What came out of it
The customer received production-ready motor controllers for all three actuator form factors, integrating directly into their robotics platform.
The daisy-chain CAN-FD architecture enables simultaneous control of multiple actuators from a single host adapter, with sub-millisecond latency in control feedback.
The ICT/FCT concept provides the foundation for scalable series production without manual test effort. Akrodyn supported the customer on-call through the integration phase.
More projects
Got an idea or a project? Let's get started.
One hour, free of charge, by video or at our place in Zurich. We look at where the technical risks are, what can be shortened and what the next sensible step would be. No pitch, no slide deck. You leave with more clarity than you arrived with — even if we never work together.
Book an engineering sparringOr get in touch directly: info@akrodyn.com · +41 44 599 20 60
You speak straight to the engineer who will work on your project afterwards.